Looking for the latest information on Behavior Trees Groot 2? We've compiled comprehensive data, records, and insights about Behavior Trees Groot 2.
Important Facts
Explore the primary sources for Behavior Trees Groot 2.
Recent Updates
Stay updated on Behavior Trees Groot 2's newest achievements.
Installing and Using Groot2
Behavior Trees in Robotics (Part 2 - C++ Implementation)
Behaviour Tree, Move based flex, and Groot are mixed
Behavior Trees (C++) + ROS 2 + Groot
Behavior Trees for Home Service Robotics Tasks – Sebastian Castro (BTs in robotics, seminar #3)
Behavior Tree BT.CPP + Groot with Navigation2
Groot with behavior tree using cpp for autonomous navigation
Behavior Tree, Groot2, Gazebo and Turtlebot3
Behavior Trees in Robotics (Part 1 - Concept)
Behavior Trees vs Finite State Machines (BT intro part 4)
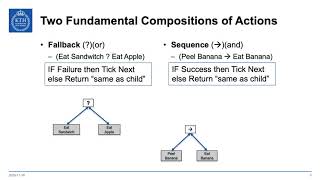
How to create Behavior Trees using Backward Chaining (BT intro part 2)
Expert Insights
Data is compiled from public records and verified media reports.
Last Updated: September 22, 2026
Final Thoughts
For 2026, Behavior Trees Groot 2 remains one of the most talked-about information profiles. Check back for the latest updates.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
This is a 5 minute introduction to See a TurtleBot3 mobile robot in the Gazebo simulator navigating an environment using In this project, AMR is using the Aplicación de Ejemplo simulando un comportamiento propio de un robot de limpieza, usando Árboles de Comportamiento, ... We are still a long way from having general-purpose robots in our homes, but this vision aims to improve our quality of life, ... Integrating NAV2 feature in ROS2 using In this video we compare the benefits and drawbacks of Finite State Machines (FSMs) and Backward chaining is a classical AI planning approach. It creates sequence of actions that leads to a given goal. In this video we ...