Looking for the latest information on Bug2 Path Finding Algorithm Ros? We've gathered comprehensive data, records, and insights about Bug2 Path Finding Algorithm Ros.
Important Facts
Explore the key sources for Bug2 Path Finding Algorithm Ros.
Recent Updates
Stay updated on Bug2 Path Finding Algorithm Ros's newest achievements.
“Bug 2” algorithm | Gaezbo + ROS | Two wheeled mobile robot
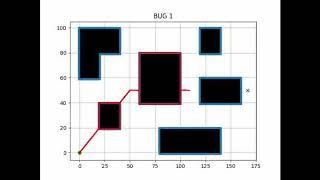
Local Path Planning with obstacle avoidance using Bug 2 Algorithm
The Most Basic Pathfinding Algorithm, Explained
A* Pathfinding (E01: algorithm explanation)
“Bug 2” algorithm | Gazebo + ROS | Two wheeled mobile robot
Bug2 ROS Simulation
[ROS Projects] Bug 2 - Exploring ROS with a 2 wheeled robot #Part 12
Bug-2 Algorithm
Simulation of the BUG2 algorithm on a Turtlebot using the Gazebo
Data is compiled from public records and verified media reports.
Last Updated: September 19, 2026
Future Outlook
For 2026, Bug2 Path Finding Algorithm Ros remains one of the most searched-for information profiles. Check back for the latest updates.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
Github github.com/KirillGordievich/bug_algorithms_gazebo. A 2 wheeled robot is equipped with a 2D laser range code: github.com/Miziziziz/GodotBreadthFirstSearch - Support Me - Buy my games: ... Welcome to the first part in a series teaching Call the line from the starting point to the goal the m-line 1) head toward goal on the m-line 2) if an obstacle is in the