Looking for the latest information on Testbed 2014 Task 6? We've gathered comprehensive data, records, and insights about Testbed 2014 Task 6.
Key Details
Explore the primary sources for Testbed 2014 Task 6.
Latest News
Stay updated on Testbed 2014 Task 6's newest achievements.
Testbed 2014 Task 2
Testbed 2014 Task 3
Testbed 2014 Task 5
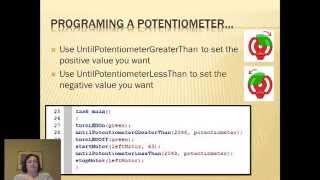
Testbed 2014 Task 5 Potentiometer
Testbed 2014 Task 4
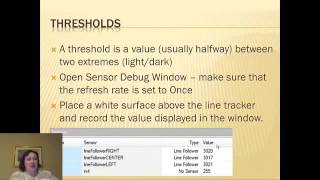
Testbed 2014 Task 1 Intro
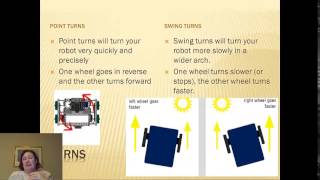
Testbed 2014 Task 3 Point Turns Swing Turns
Testbed 2014 Task 4 Touch Sensors
Testbed 2014 Task 2 Directions of Motors
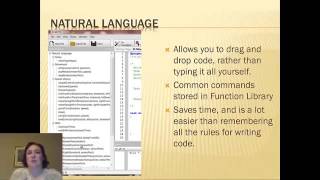
TestbedProg3
TestbedProg1
Detailed Analysis
Data is compiled from public records and verified media reports.
Last Updated: September 22, 2026
Future Outlook
For 2026, Testbed 2014 Task 6 remains one of the most talked-about information profiles. Check back for the latest updates.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
How to use RobotC to program a potentiometer to turn on and off a motor. In this case the potentiometer is being used a ... How to get RobotC to run a motor backwards. Using RobotC to simulate point turns and swing turns with a VEX Wait 5.0 means wait five seconds stop the motor the ... program a switch you can add an until touch which will make your ... so I want you to stop here do