Navigation (& Waypoint Navigation) using saved map | Turtlebot3 Waffle
How to Create the Map using SLAM in turtlebot3 ( Realtime)
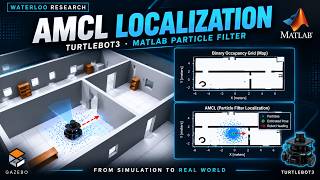
TurtleBot3 AMCL Localization in MATLAB | Particle Filter Demo
Turtlebot3 SLAM - Research Result
Turtlebot 3 Waffle Pi test
TurtleBot3 AutoRace 2020 for Noetic] Mission 3: Construction
TurtleBot3 85 Using Raspberry Pi Camera with TurtleBot3
Deep Dive
Data is compiled from public records and verified media reports.
Last Updated: September 22, 2026
Conclusion
For 2026, Turtlebot3 Update remains one of the most searched-for information profiles. Check back for the newest reports.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
Hey hello everybody I'm going to try to do a Facebook live 스마트팜 자동 운송 로봇 및 충전 스테이션 연계 시스템. Learn how to set up SLAM and Navigation for Using Python/ROS to autonomously avoid obstacles, search for targets using computer vision, and bring them to a goal location. Env.OS : Ubuntu 16.04 ROS : kinetic ref : emanual.robotis.com/docs/en/platform/ How many sensors do you know? How to use its with In this tutorial, you will learn how to to the /odom (Odometry) topic in ROS 2 while controlling a If there is some issue in loading the map even if path/global path is correct, try sudo apt This video demonstrates Adaptive Monte Carlo Localization (AMCL) using a This video results from our testing from conducting a SLAM experiment in our Testing a new robot in our lab of Electronic Engineering, University of Nis, Serbia. Papers related to our work on robot ... Simulating the Construction Mission for Noetic. Source code ... You can use a Raspberry Pi camera with the




![TurtleBot3 AutoRace 2020 for Noetic] Mission 3: Construction](https://i.ytimg.com/vi/pO9SXz7ad7M/mqdefault.jpg)

