Overview on Universal Robot Rtde Tutorial 6 Full Program Implementation Part 3 4
Looking for the latest information on Universal Robot Rtde Tutorial 6 Full Program Implementation Part 3 4? We've compiled comprehensive data, records, and insights about Universal Robot Rtde Tutorial 6 Full Program Implementation Part 3 4.
Main Features
Explore the primary sources for Universal Robot Rtde Tutorial 6 Full Program Implementation Part 3 4.
Recent Updates
Stay updated on Universal Robot Rtde Tutorial 6 Full Program Implementation Part 3 4's newest achievements.
Universal Robot RTDE tutorial #4 (Full program implementation Part 1/4) Servoj/inv_kin()
Universal Robots UR3 - Process Tasks 2 in RoboDK
Universal Robot RTDE tutorial #2 (Example program from UR)
Universal Robot RTDE tutorial #1 (Where to start the journey)
Universal Robots Technical Demo Part 6
How to Connect your PC to a Physical Robot using RTDE
Face tracking with python using RTDE communication | Universal Robot UR5e
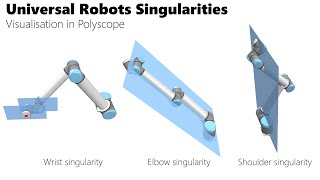
Universal Robots Singularities: Visualisation in Polyscope
Simulate Universal Robots with RTDE Connection
Making world's best URDF Using IMU data in URDF
Efficient Programming for UR Robots
Expert Insights
Data is compiled from public records and verified media reports.
Last Updated: September 21, 2026
Final Thoughts
For 2026, Universal Robot Rtde Tutorial 6 Full Program Implementation Part 3 4 remains one of the most searched-for information profiles. Check back for the newest reports.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
github.com/danielstank/Servoj_RTDE_UR5.git. So basically how we use servo j is we have point a we have point b we want the Master's degree - Alen Kolman The master's degree presents an analysis of the collaborative ... address and type it over here Within this video, we will be discussing how to get your PC connected to a Physical Turin polytechnic university in Tashkent, Mechatronics Center. ISO-10218 defines a singularity as a ”condition caused by the collinear alignment of two or more This video shows how to connect a Making world's best URDF. Using IMU data in URDF • visualizing IMU data • texturing in Blender • controlling gripper through RViz ...
Universal Robot Rtde Tutorial 6 Full Program Implementation Part 3 4.pdf
What is the most accurate information about Universal Robot Rtde Tutorial 6 Full Program Implementation Part 3 4?
Our platform aggregates the most comprehensive and up-to-date insights, ensuring you get relevant details about Universal Robot Rtde Tutorial 6 Full Program Implementation Part 3 4.
Why is Universal Robot Rtde Tutorial 6 Full Program Implementation Part 3 4 trending right now?
Interest in Universal Robot Rtde Tutorial 6 Full Program Implementation Part 3 4 has surged recently as more people seek reliable resources, related media, and detailed analysis.
Where can I find related media and updates for Universal Robot Rtde Tutorial 6 Full Program Implementation Part 3 4?
You can explore extensive galleries, video summaries, and related content directly on this page.
How often is the content about Universal Robot Rtde Tutorial 6 Full Program Implementation Part 3 4 updated?
We regularly update our database with the latest information, media, and analysis related to Universal Robot Rtde Tutorial 6 Full Program Implementation Part 3 4.