Looking for the latest information on Graph Based Slam? We've gathered comprehensive data, records, and insights about Graph Based Slam.
Core Information
Explore the key sources for Graph Based Slam.
History
Stay updated on Graph Based Slam's latest milestones.
Understanding SLAM Using Pose Graph Optimization | Autonomous Navigation, Part 3
Wolfram Burgard, Giorgio Grisetti, and Cyrill Stachniss: Graph-based SLAM in 20 Minutes
Graph Based SLAM and Loop Closure
Graph-based representations for Spatial-AI | Andrew Davison | Tartan SLAM Series
SLAM - 5 Minutes with Cyrill
Optimized Graph-based SLAM
Graph SLAM with occupancy grid - ISAM FLIRT in ROS
Tutorial on Graph Based SLAM G2O 论文分享 (A)
Graph based SLAM
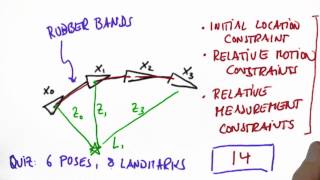
Graph SLAM Solution - Artificial Intelligence for Robotics
Graph-based SLAM on pose-pose data
Full Guide
Data is compiled from public records and verified media reports.
Last Updated: September 20, 2026
Conclusion
For 2026, Graph Based Slam remains one of the most talked-about information profiles. Check back for the newest reports.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
This video is part of an online course, Intro to Artificial Intelligence. the course here: ... This video provides some intuition around Pose This is a short video lecture by Wolfram, Giorgio, and Cyrill explaining Filtering methods the Extended Kalman Filter fail due to quadratic complexity in state size. A presentation by Andrew Davison as part of the Tartan Shows introductory material relating to solving the Simultaneous Localization and Mapping ( The robot is estimating its pose and surrounding map simultaneously. The map is represented as a occupancy grid. Under the ... The idea of assignment 10 of Robot Mapping taught by Dr. Cyrill Stachniss is to iterate through Newton-Gauss optimization ...