Looking for the latest information on Particlefilter Localization? We've gathered comprehensive data, records, and insights about Particlefilter Localization.
Main Features
Explore the primary sources for Particlefilter Localization.
Latest News
Stay updated on Particlefilter Localization's latest milestones.
Particle Filter Localization (AMCL) | ROS2 Navigation WITHOUT Nav2**
How to Teach ROS 2 AMCL Localization: Particle Filter on a Known Map
Particle Filter Localization | P2m06
Particle Filter Landmark Localization
ParticleFilter Localization
Particle Filter Localization and The Kidnapped Robot Problem Part I (Known Data Assignment)
Particle Filter - 5 Minutes with Cyrill
Localization with Particle Filters
Particle Filter for Localization
Unity Particle Filter for 2D Real-Time Localization
MSR Course - 07 Particle Filter (Stachniss)
Deep Dive
Data is compiled from public records and verified media reports.
Last Updated: September 22, 2026
Final Thoughts
For 2026, Particlefilter Localization remains one of the most talked-about information profiles. Check back for the newest reports.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
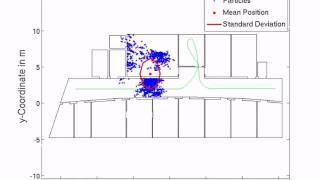
This is the first video in a series of videos about robot Watch the first video in this series here: youtu.be/Fw8JQ5Q-ZwU This video presents a high-level understanding of the ... Starting from a unknown position represented by the uniformly scattered particles, the distribution gradually converges as the ... After building a map for navigation, the next challenge is determining where the robot is located on that map — without ... The aim of this project is to estimate the state of a moving object (its X and Y position and orientation) using a References: 1. Thrun, S. (2002). Probabilistic robotics. Communications of the ACM, 45(3), 52-57. Udacity Self Driving Car Nanodegree -- Term 2 Project 3 Github Code ... At first I was wondering, how do you compare the two vectors of distance. Then I had a thought, each element in the vector is just ...